Skip to content
Noah SpiegelmanMechanical engineering

Mechanical engineering portfolio

Making ideas hold up under load.

I'm a junior at Boston University studying mechanical engineering with a robotics concentration. I design and build hardware, model how it moves, and write the software that makes sense of what it measures.

Seeking Summer 2027 internships in robotics, mechanical design, and prototyping.

  • Boston University
  • Mechanical engineering
  • Robotics concentration
  • Class of 2028
GROUND 7.000 IN110°COUPLER 6.000ROCKER 4.240CRANK 2.000
110°
Fig. 01The four-bar linkage from my ME357 axe project, solved live from its CAD dimensions. Drag the orange crank pin or use the slider.

Selected work

Robots, sensors and structures

Research, team and course projects, from a quadruped robot to a truss designed to resist buckling.

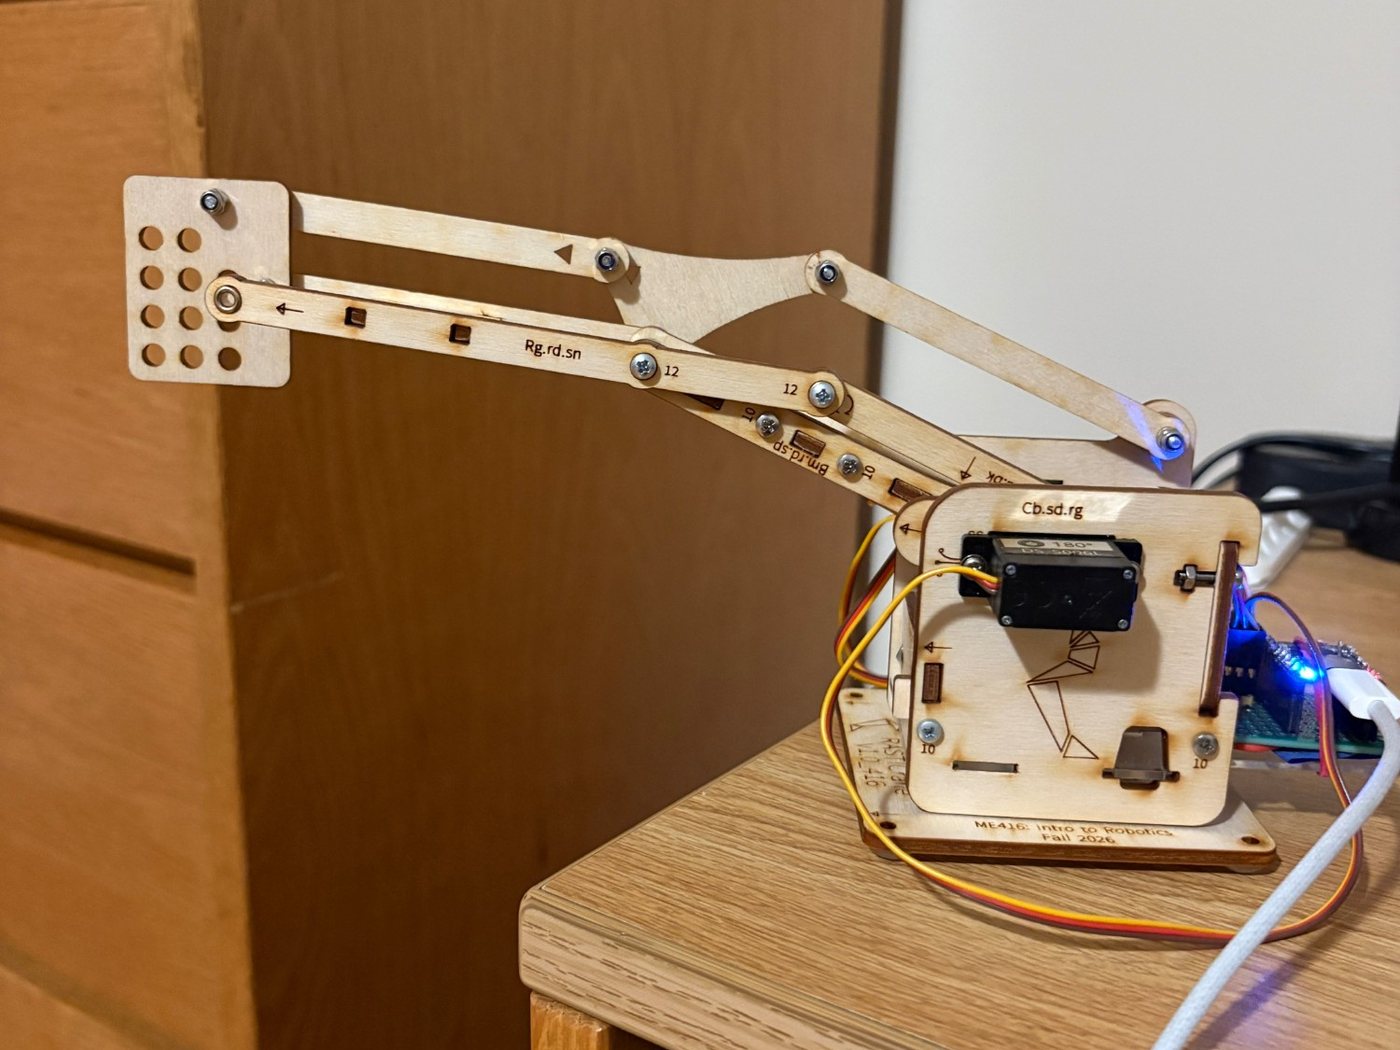
  1. Side view of the wooden robotic arm reaching out to the left from its base, with three servo wires and a USB cable running to the ESP32 board on the right
    Completed
    Exhibit 01Fall 2026

    Robotics · Computer vision

    RASTICrane. View project

    A laser-cut robotic arm turned into a vision-guided stamp machine, using AprilTags and inverse kinematics.

    2.565 mm

    Mean landing error

    Measured
    Role
    Assembly, calibration and testing; code written with an AI model (team of two)
    Tools
    ESP32 · Arduino (C++) · Servo motors · Soldering · MQTT

    3D CAD viewer and interactive inverse-kinematics demo

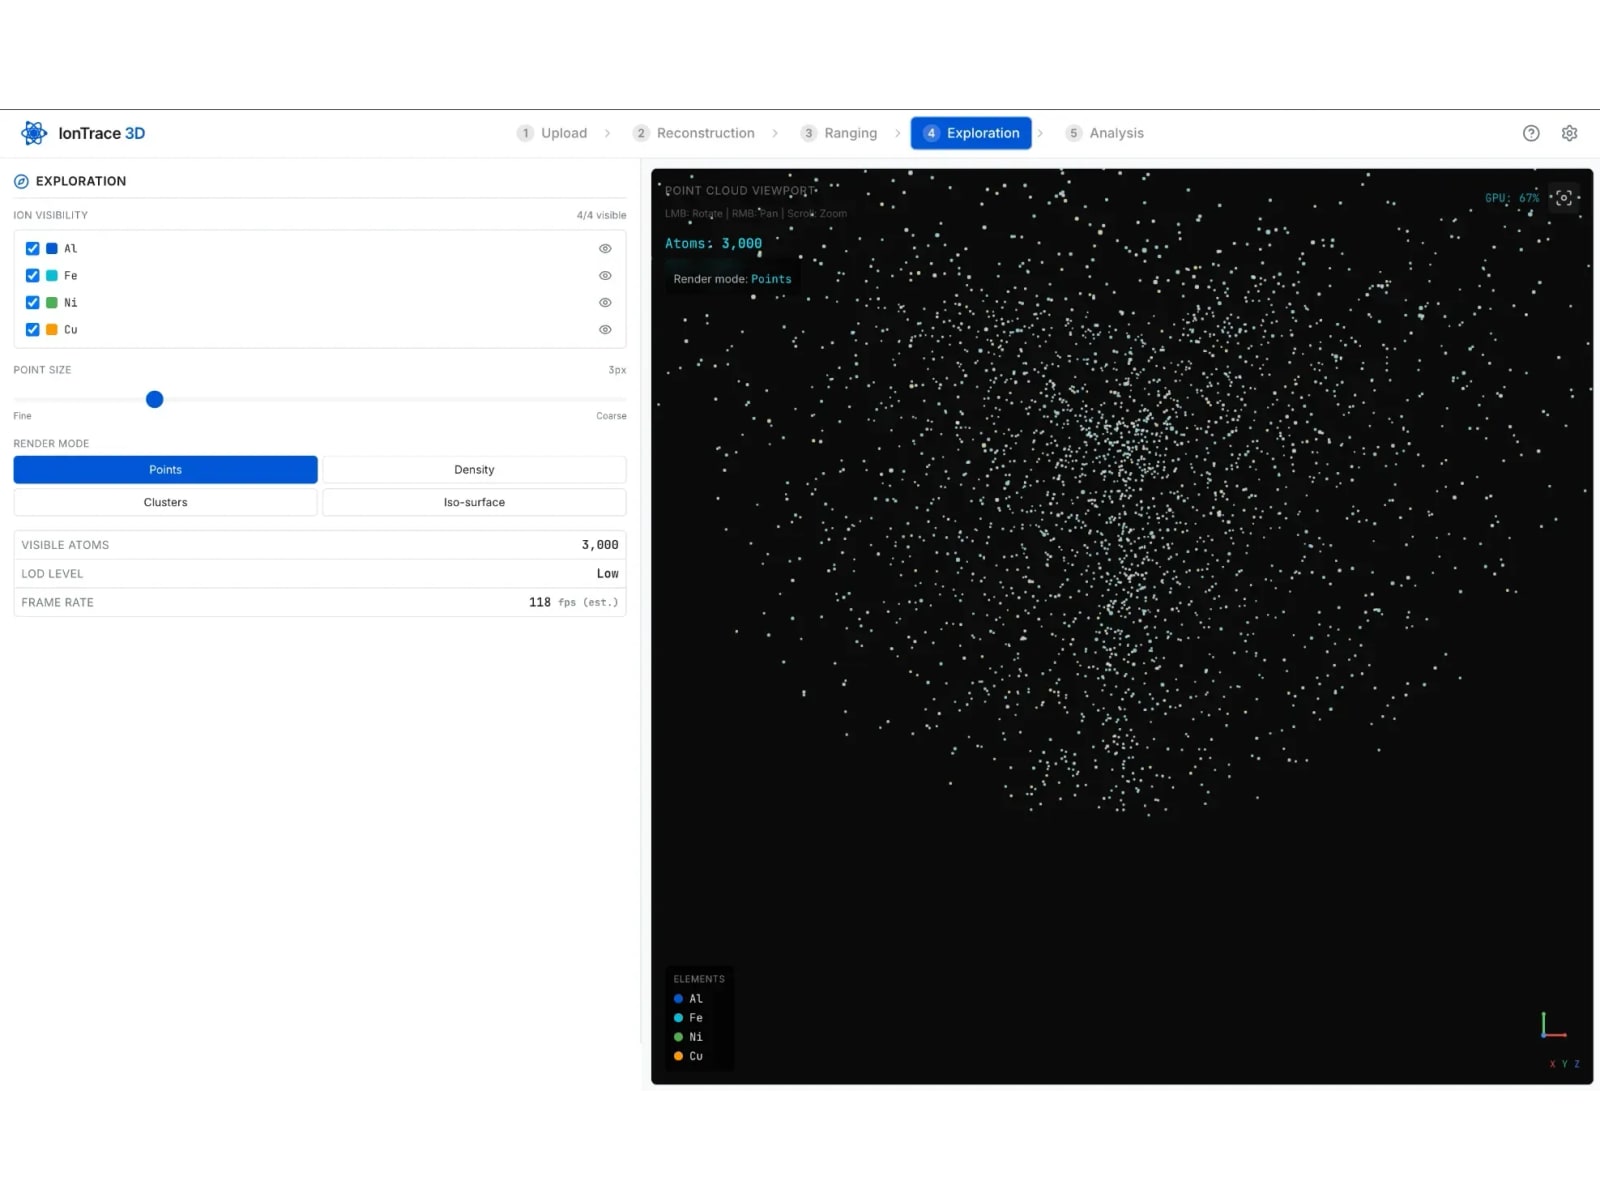
  2. IonTrace's Exploration step: ion species toggles, point size and render mode controls on the left, and a 3D point cloud of 3,000 atoms in the viewport
    Completed
    Exhibit 02Jan 2026 – Jun 2026

    Scientific visualization · Research software

    IonTrace. View project

    A browser-based, AI-assisted GUI for loading, reconstructing and exploring atom probe tomography datasets.

    7

    APT file formats loaded

    Delivered
    Role
    Research intern and IonTrace developer
    Tools
    Next.js · TypeScript · Python · Xe plasma FIB-SEM
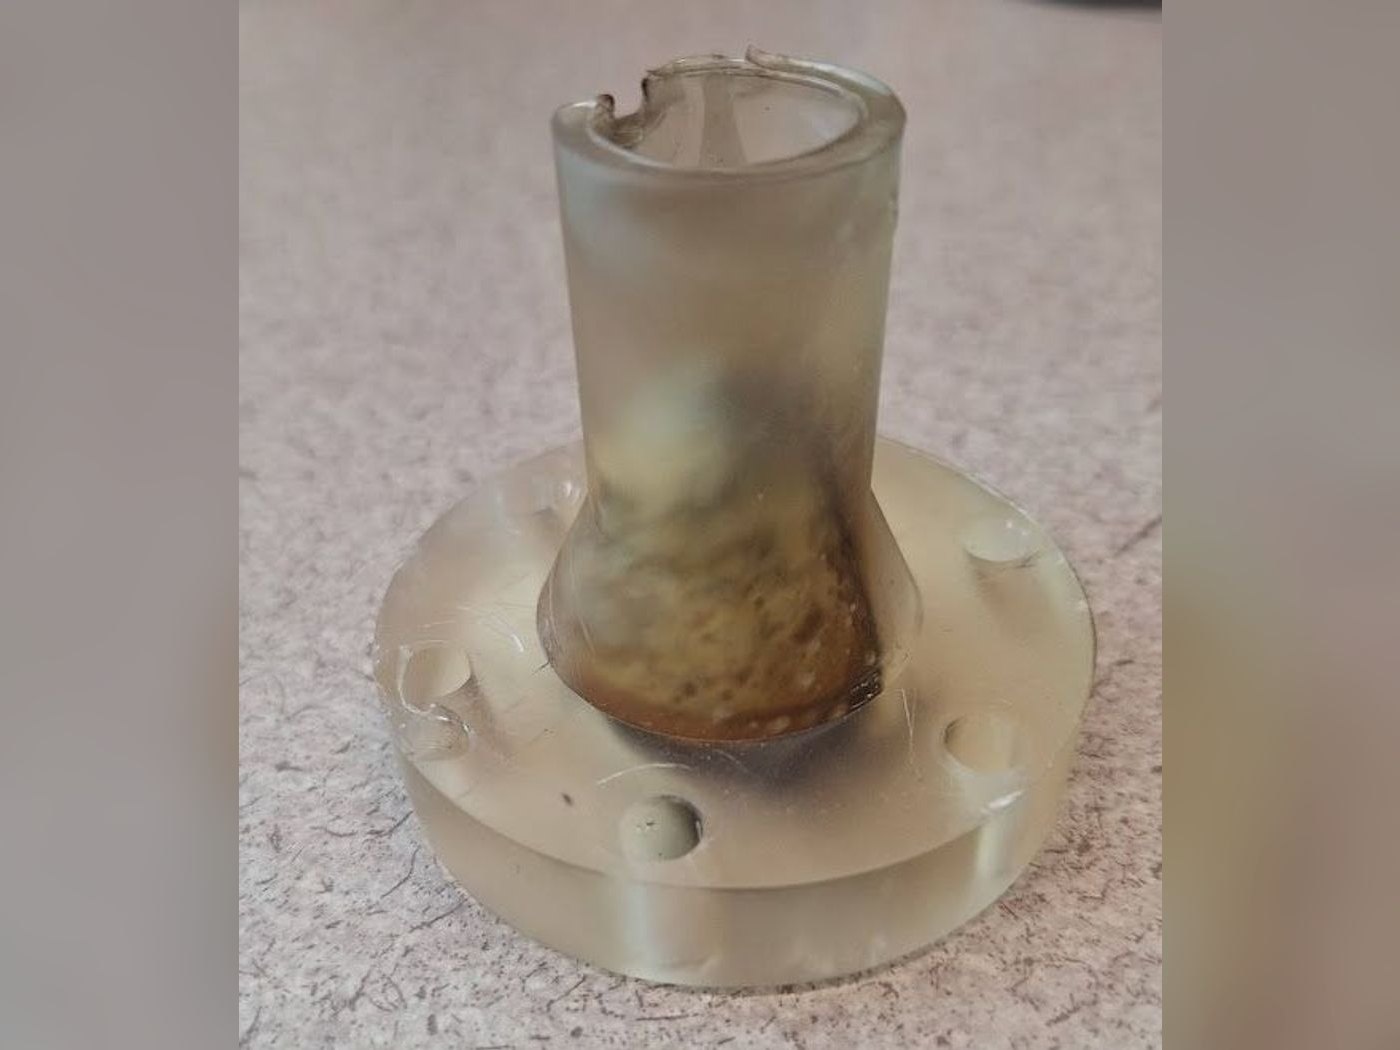
  3. The 3D-printed translucent resin nozzle standing on a table after its hot-fire test, with a scorched, discolored bore and a chipped exit rim
    Completed
    Exhibit 03Fall 2024

    Propulsion · Design, FEA and testing

    Rocket Nozzle. View project

    A 3D-printed rocket nozzle sized with isentropic flow equations, checked in FEA to a minimum factor of safety of 2.1, and hot-fired on a test stand.

    2.118

    Minimum factor of safety

    Simulated
    Role
    Team member (team of 5): design, CAD, FEA, 3D printing and testing
    Tools
    SolidWorks · SolidWorks FEA · 3D printing (ABS-like resin) · Arduino Uno

Currently building

SCOUT Quadruped Robot. View project

RASTIC · Boston University · Sep 2026 – present

A low-cost quadruped with a 4-DOF camera arm, being built as a search-and-rescue support prototype.

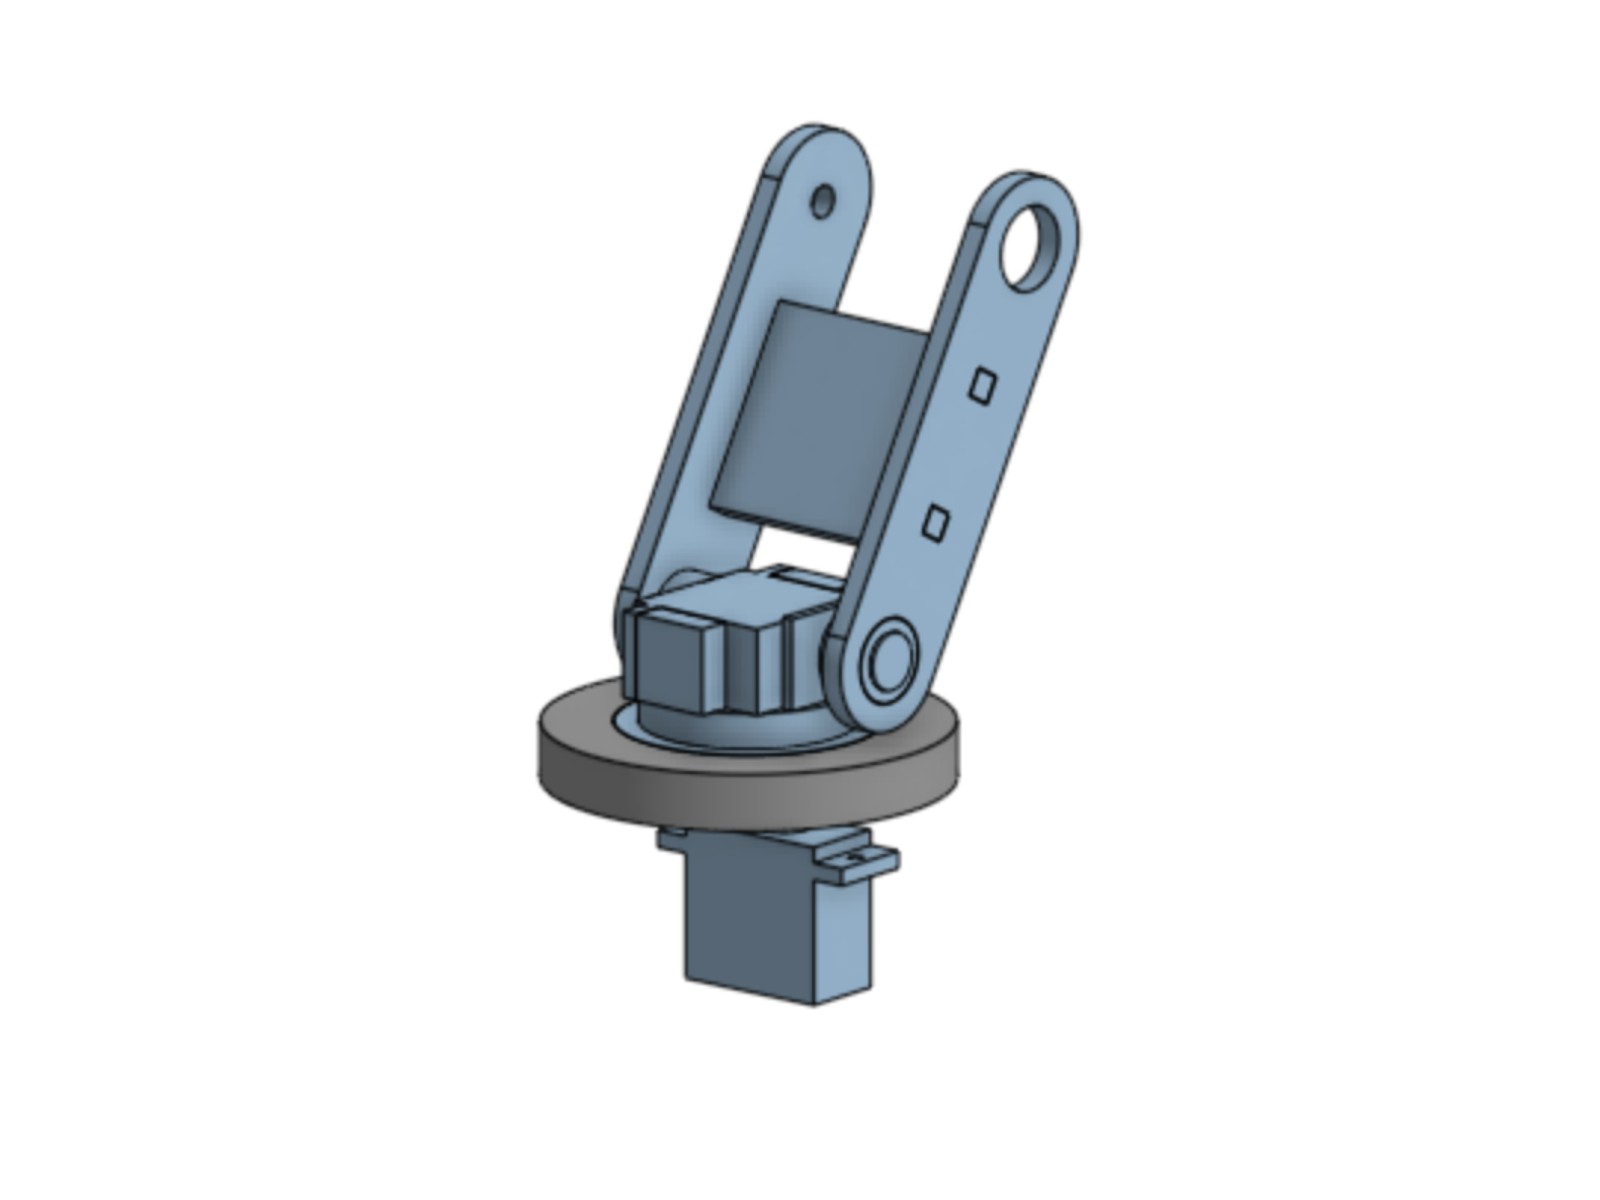
CAD render of the 4-DOF robotic camera mount: a two-link arm on a servo turret, angled upward

My part

4-DOF camera arm: mechanical design, electronics and camera mounting

In progress now

  • CAD of a single 3-DOF leg
  • Design of the 4-DOF camera mount (current CAD concept shown above)

Planned, not yet built

  1. One leg and the arm working, with servo control, basic voice interaction and camera access
  2. Chassis and four legs, with inverse kinematics and an initial walking gait
  3. Integration of cameras, distance sensing, communication, inventory tracking and the operator GUI
  4. Controlled demonstrations, with results and limitations recorded
  5. Presentation at RASTIC, evaluation and a plan for the next version

$500

Parts budget

Planned

More projects

Course and team projects, filterable by discipline.

Filter

4 of 4 projects

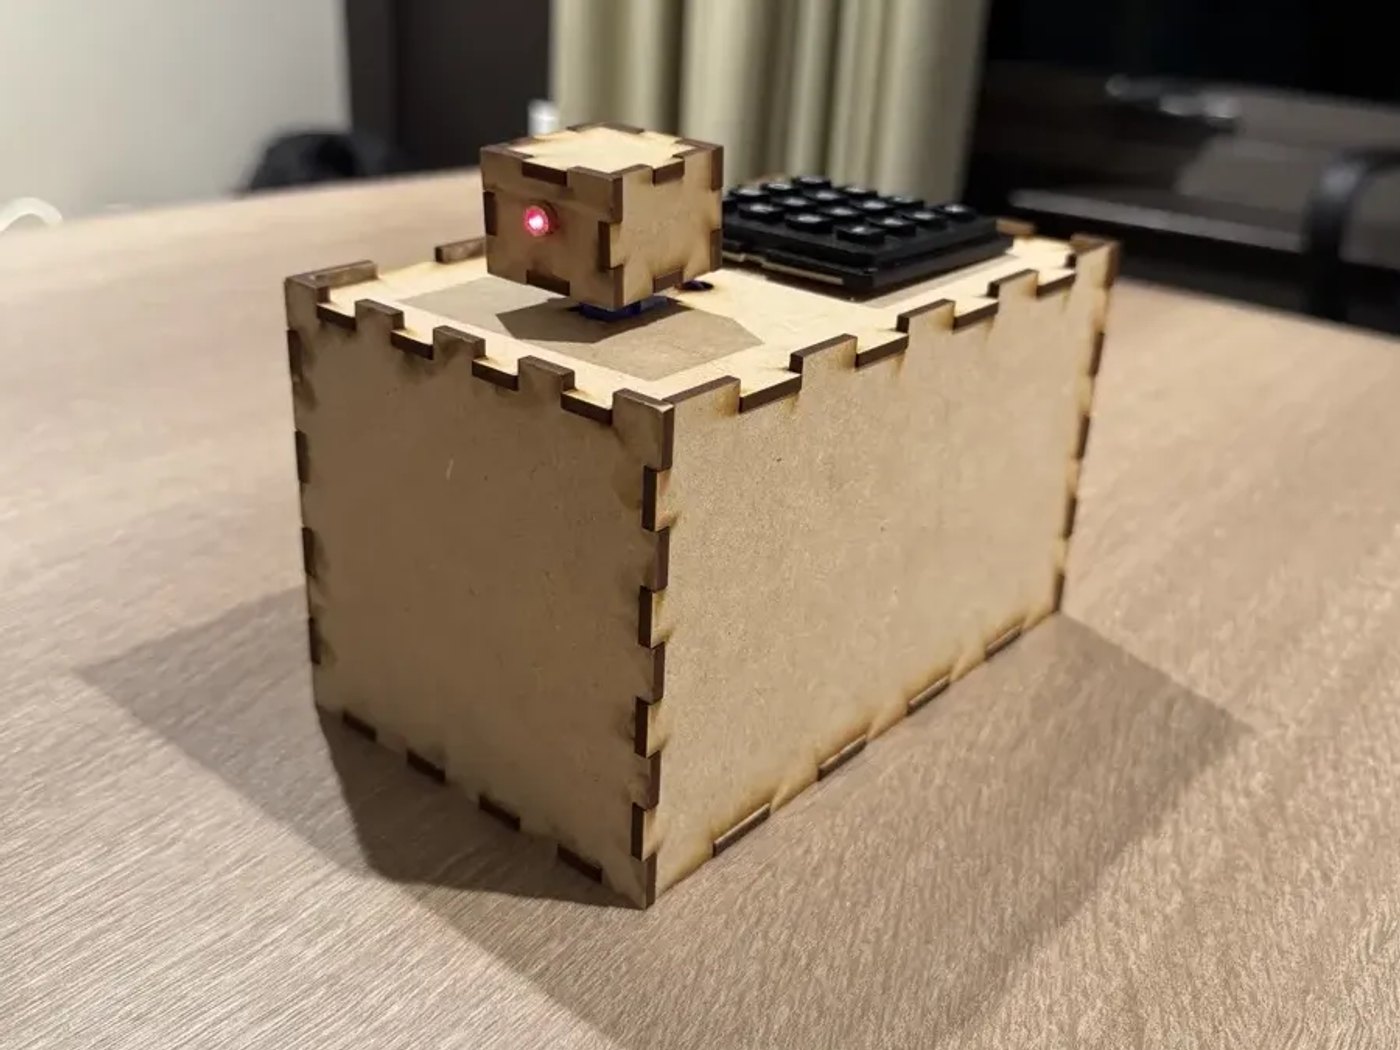
The finished transmitter, a laser-cut box with a 16-key keypad and a small servo-mounted laser housing on its lid, with the red laser dot lit
Completed

Mechatronics · Optical communicationSep 2025 – Dec 2025

Point-to-Point Communication System. View project

A keypad-to-LCD laser Morse-code link built from two Arduinos, with a servo-steered transmitter.

20 / 20

Messages decoded at 1–5 ft

Measured

Interactive Morse-over-light demo

  • Embedded
  • Mechanical
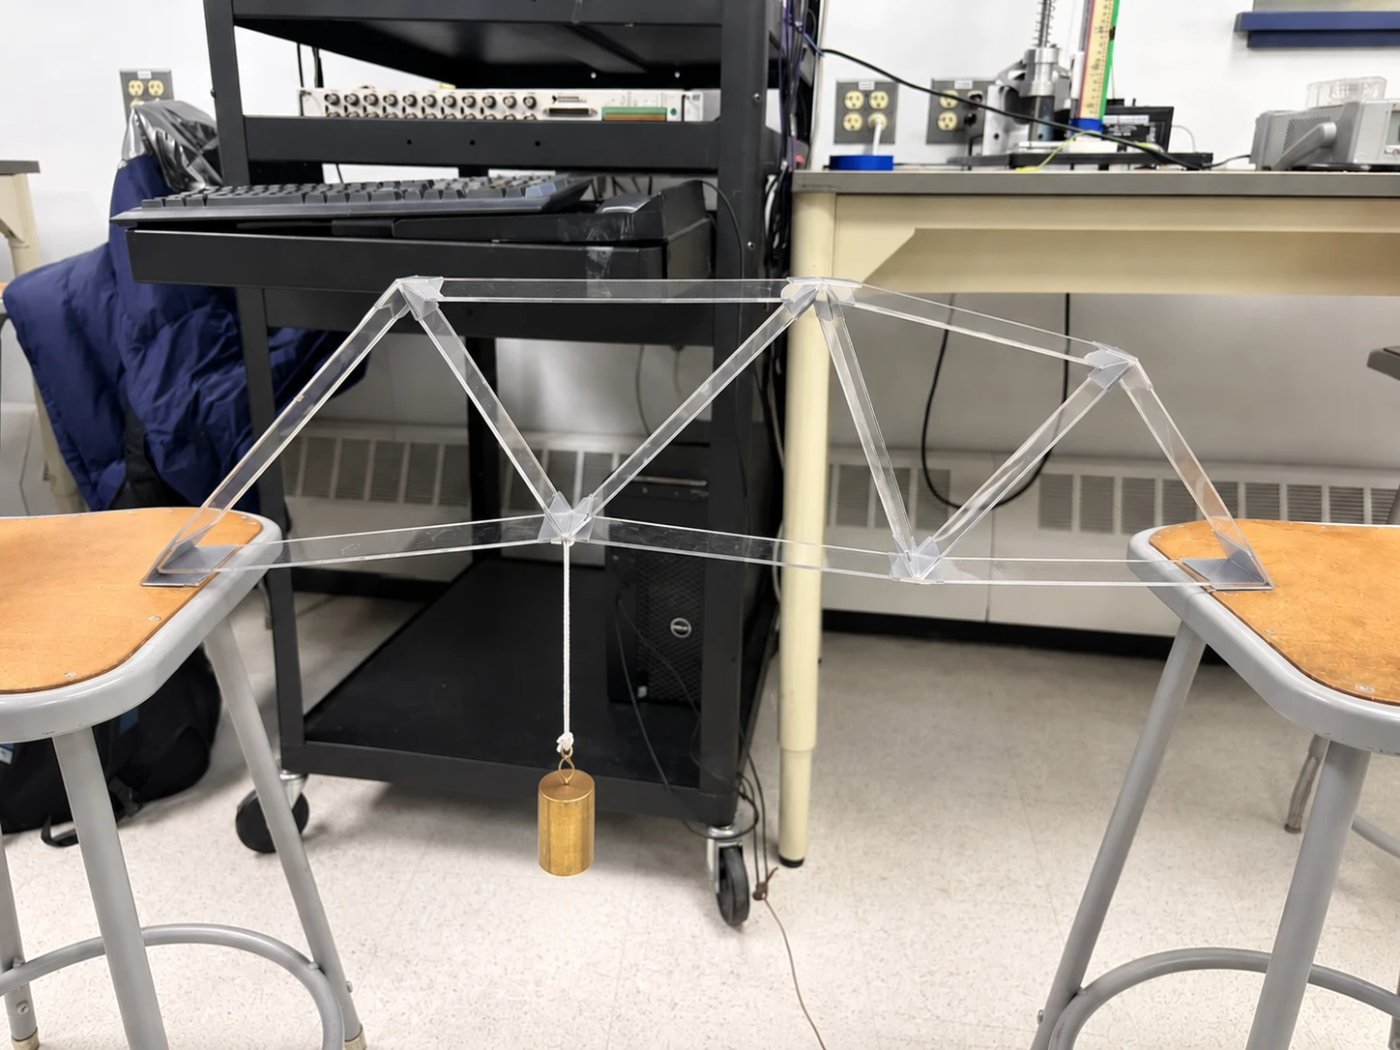
The physical acrylic truss resting on two lab stools during load testing, with a weight hanging from its center joint
Completed

Structural analysis · OptimizationFall 2025

Truss Design: Buckle Up. View project

A planar acrylic truss optimized in MATLAB to carry the highest load before buckling.

46.59 oz

Predicted maximum load

Predicted
  • Simulation
  • Mechanical
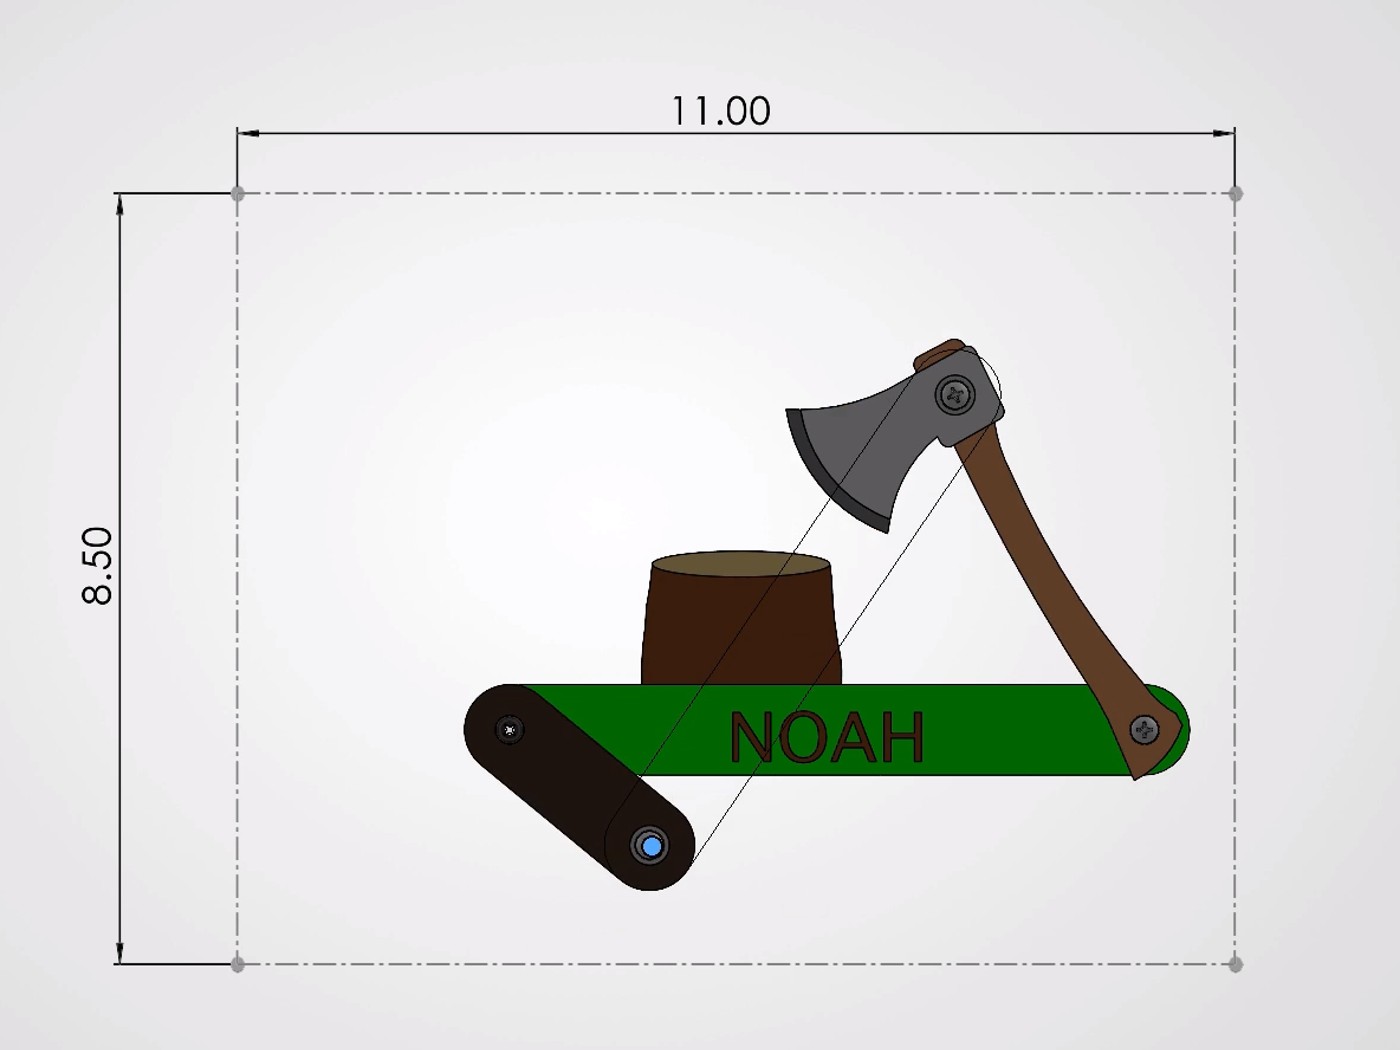
SolidWorks render of the axe linkage with the axe raised above a stump on a green base engraved NOAH, inside a dashed 11 by 8.5 inch boundary
Completed

Mechanism design · CADFall 2025

Four-Bar Axe Linkage. View project

A four-bar linkage designed as a swinging axe, with a SolidWorks motion study inside a letter-size page.

56°

Rocker swing

Simulated

Live four-bar solver and 3D CAD viewer

  • Mechanical
  • Simulation
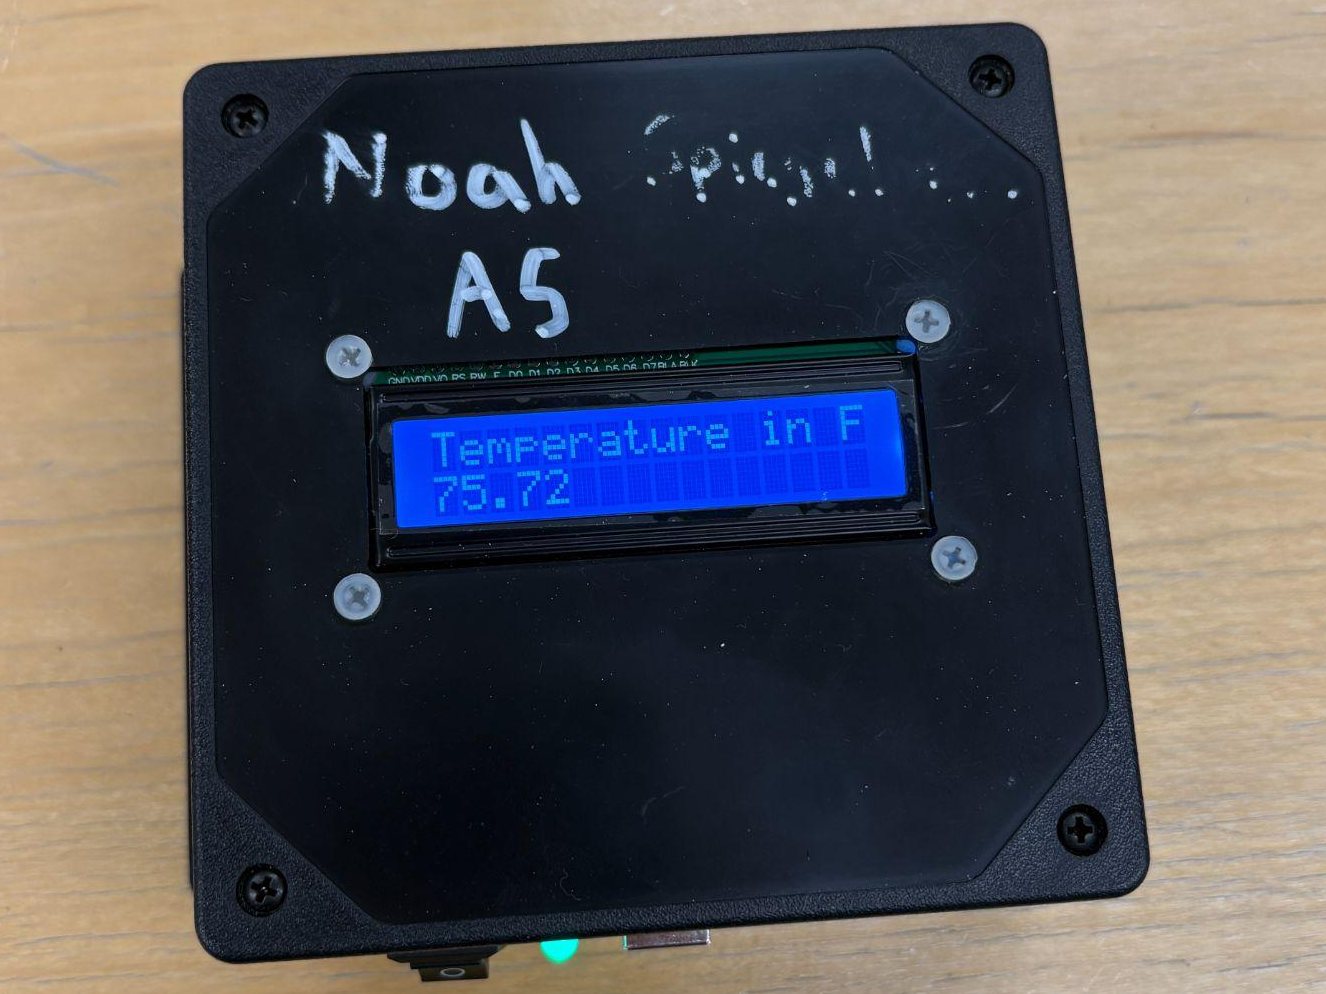
The finished black enclosed temperature monitor on a table, with a blue 16 by 2 LCD reading Temperature in F, 75.72, and a green power LED lit at the edge
Completed

Embedded systems · Enclosure designJan 2025 – May 2025

Ambient Temperature Sensor. View project

A battery-powered Arduino room-temperature monitor with an LCD readout and LED and buzzer alerts.

≈ 6 h

Estimated battery life

Predicted
  • Embedded
  • Mechanical

Making & fabrication

Built by hand

Personal builds outside coursework, made with hand tools, a table saw and CAM software.

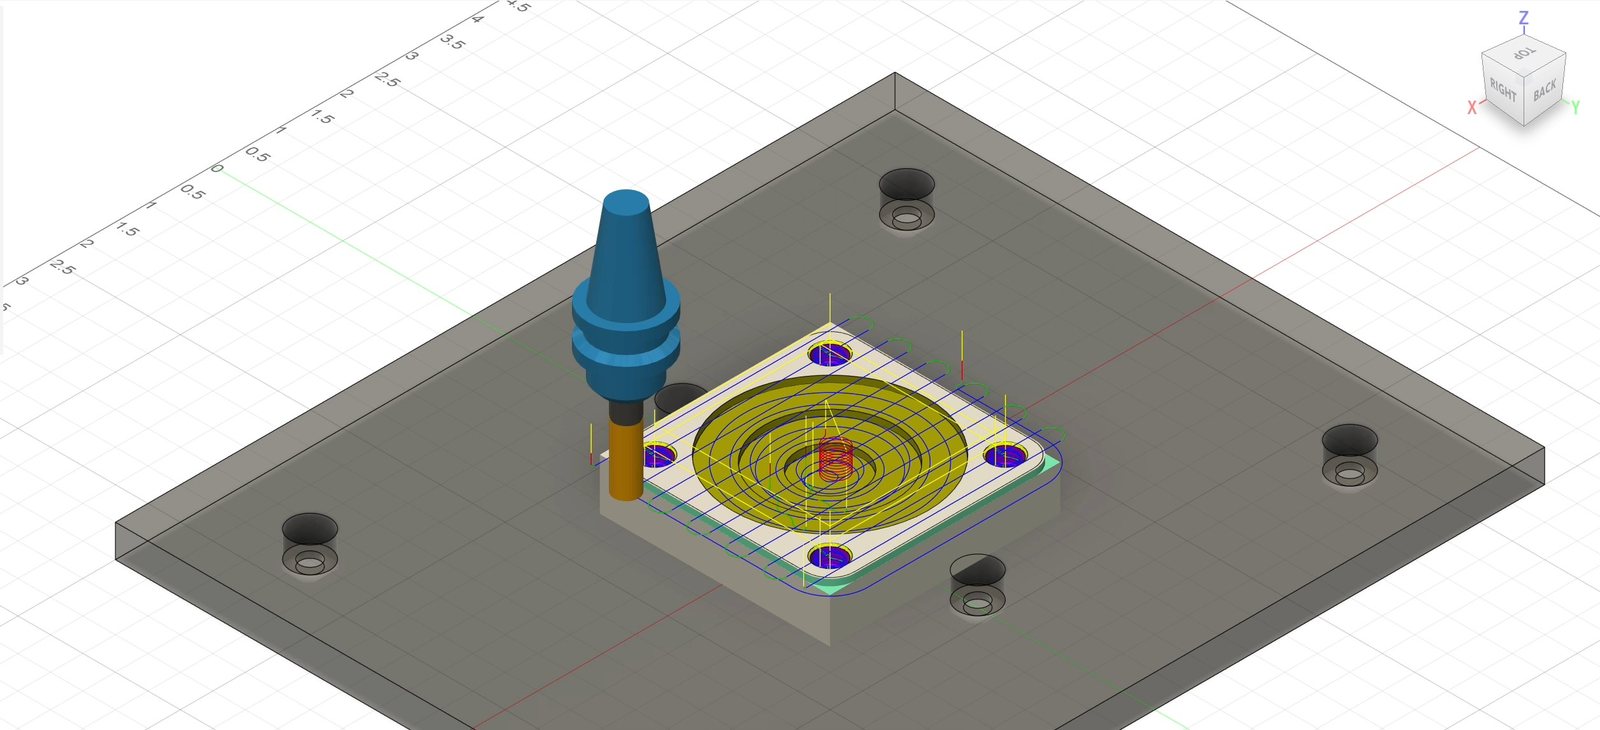
Fusion 360 CAM simulation of a spindle over a square coaster blank with a spiral pocket toolpath cut into its face, fixtured on a larger baseplate
Completed

CAM · MachiningSep 2026 – Oct 2026

CNC Coaster. View project

A coaster toolpath programmed and simulated in Fusion 360's CAM workspace.

  • Mechanical
  • Simulation
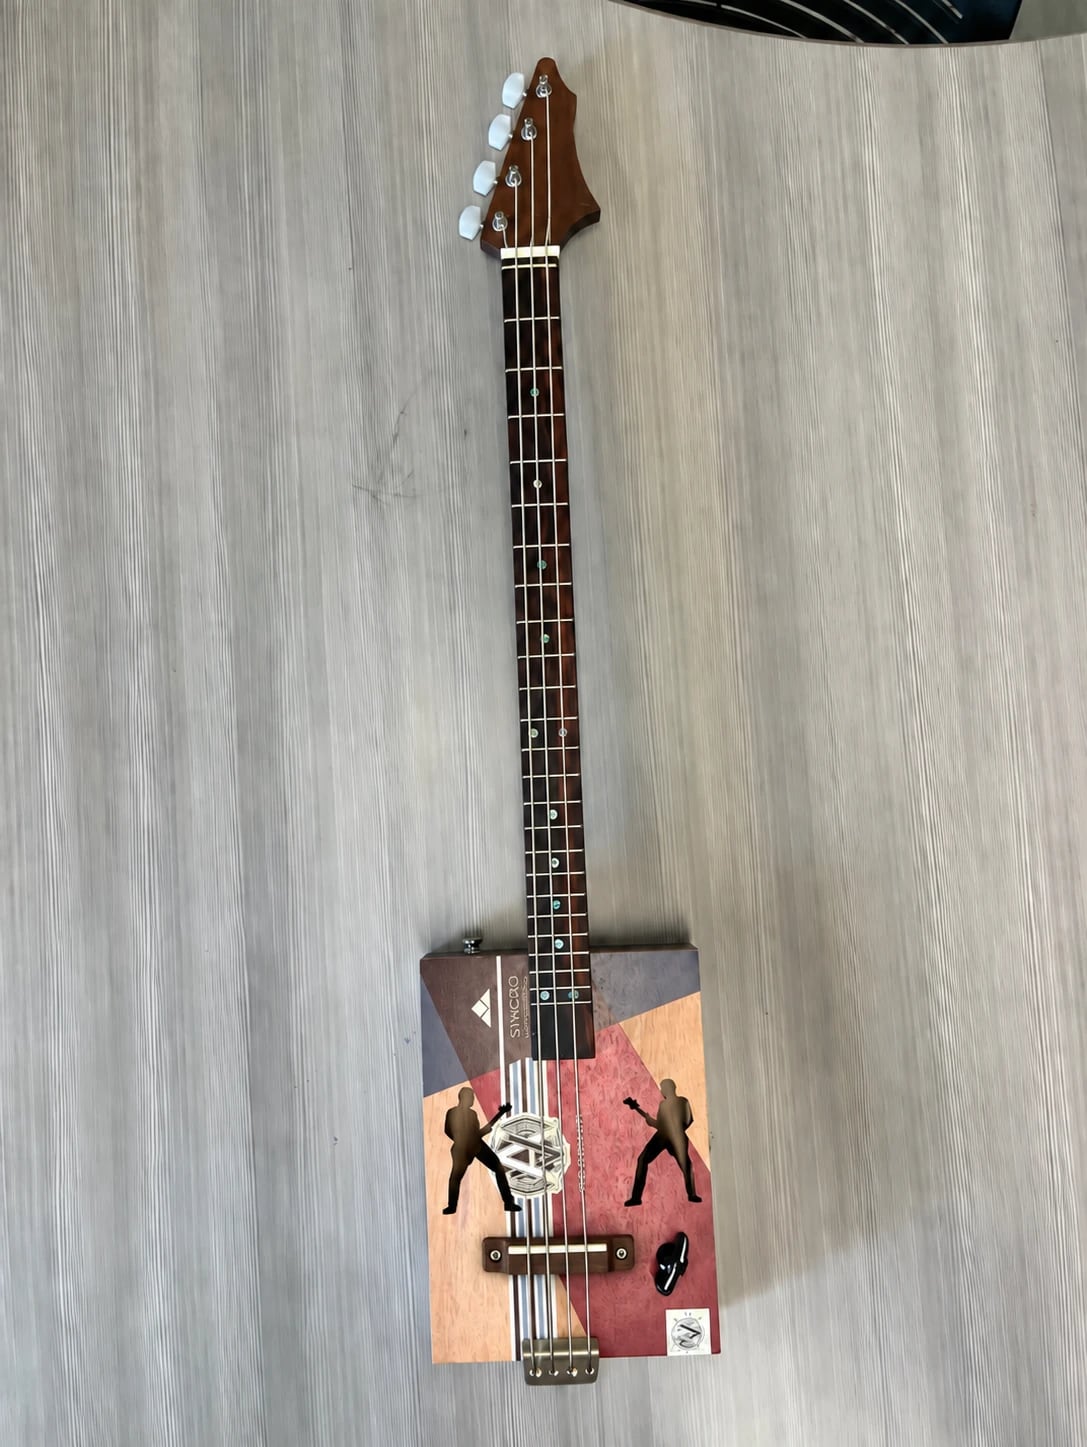
The finished cigar box guitar lying on a light wood-grain table, seen from above: a long dark fretboard with shell position markers and a pointed wooden headstock with four tuning pegs, leading down to a cigar-box body inlaid with geometric blocks of color and two guitarist silhouettes, with a wooden bridge and brass tailpiece
Completed

Hand fabrication · Instrument makingPersonal project

Cigar Box Guitar. View project

A handmade electric guitar built from a cigar box, with a hand-shaped neck, fretboard and headstock.

  • Mechanical

Experience

Where I've worked and built

Internships, research and the teams I've built with, newest first.

  1. Sep 2026 – Present

    Technical Service Team Member

    Boston University Robotics Club Boston, MA

    • Serve on the technical service team, providing hands-on technical support to club robotics projects
    • Adapt to each team's goals and quickly learn new tools to keep projects moving
  2. Sep 2026 – Present

    SCOUT project team

    RASTIC · Boston University Boston, MA

    • Own the 4-DOF camera arm of a low-cost search-and-rescue quadruped: mechanical design, electronics and camera mounting
    • Building it with two teammates, one on the body and legs and one on AI and software
    See the project: SCOUT Quadruped Robot
  3. Jan 2026 – Jun 2026

    Research Intern

    University of Sydney · Simon Ringer Research Group Sydney, Australia

    • Developed IonTrace, a browser-based software tool (Next.js/TypeScript, Python backend) that lets researchers load, reconstruct and explore Atom Probe Tomography (APT) datasets
    • Engineered an automatic down-sampling system that keeps the 3D viewer responsive on datasets with hundreds of thousands of ions
    • Supported the full APT workflow by performing SEM-based sample preparation and fabricating specimens from 3D-printed, hardened metal powders
    See the project: IonTrace
  4. Jun 2025 – Aug 2025

    Science Intern

    Tetra Tech Sacramento, CA

    • Led Environmental Release to Construction (ERTC) tailboards for 10-30 crew members per session, strengthening technical communication and public speaking skills
    • Performed compliance inspections and designated soil sampling locations on active construction sites
    • Fostered trust with crews, staff, and homeowners while de-escalating conflicts on site
  5. Fall 2024

    Team member

    Boston University Rocket Propulsion Group (BURPG) Boston, MA

    • Part of a team of 5: design, CAD, FEA, 3D printing and testing of a rocket nozzle, plus the electronics to hot-fire it
    See the project: Rocket Nozzle
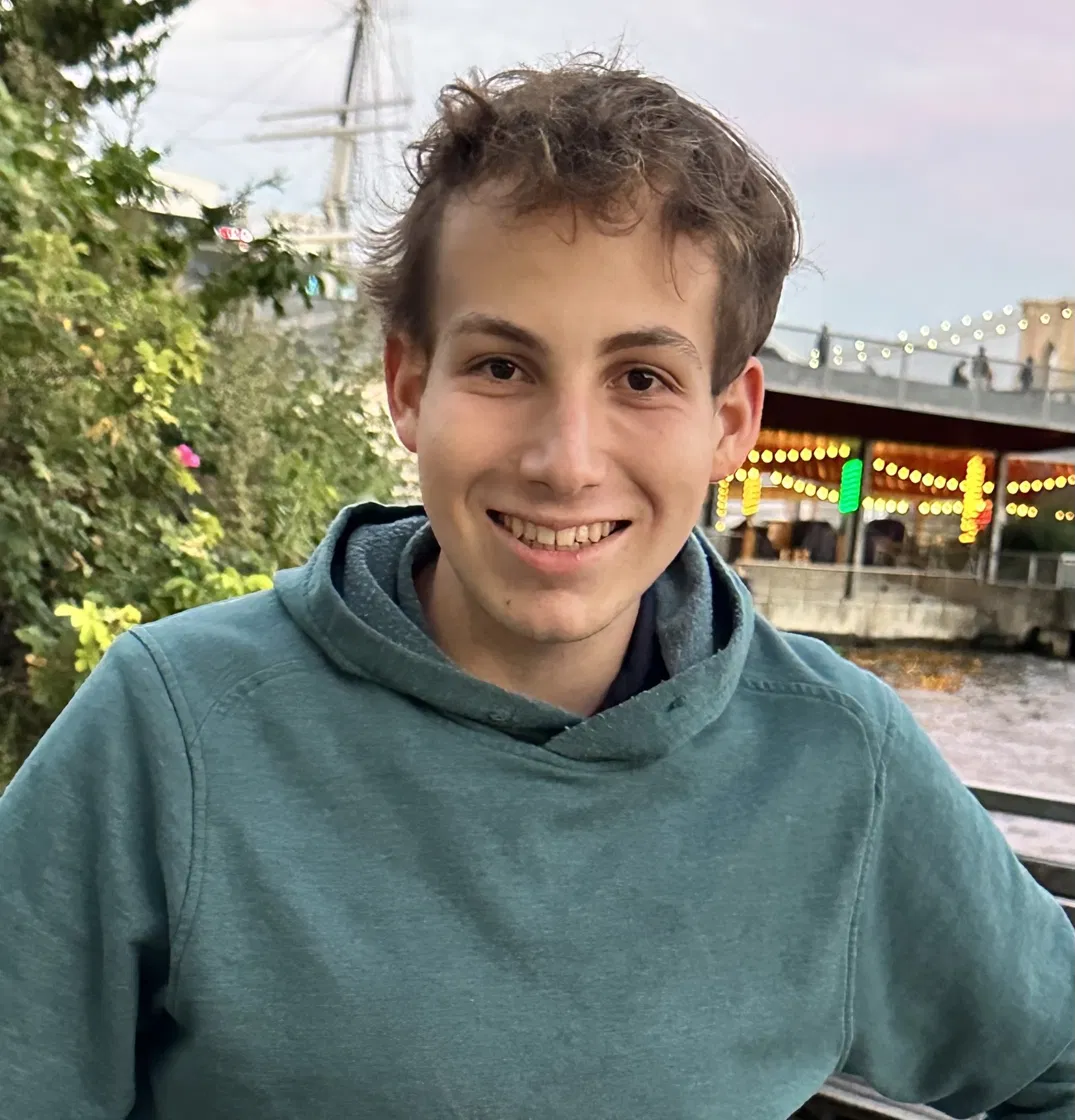
Noah Spiegelman smiling outdoors in a teal hoodie, with a waterfront behind him

About

Hands-on, and analytical

I'm a junior at Boston University, graduating in May 2028 with a 3.4 cumulative GPA. My coursework has moved from foundational mechanics and materials into manufacturing processes and robotics, with electromechanical design next.

This spring I was a research intern at the University of Sydney, where I worked through the atom probe tomography workflow and built IonTrace, a tool for exploring APT datasets. The summer before, I was a science intern at Tetra Tech in Sacramento, leading environmental-release-to-construction safety briefings for crews of 10 to 30 and performing compliance inspections on active construction sites.

Outside of coursework, I like making things by hand — most recently a cigar box guitar built from scratch: I cut and shaped the neck and headstock myself, calculated the fret spacing and cut the slots on a table saw, and wired in a piezo pickup, tuning the four strings to GDGB for a clean, warm sound. Shaping the neck freehand was the hardest part — I'm a bit of a perfectionist, so getting it exactly right took more patience than anything else in the build. It hangs on my bedroom wall now.
Contact

Let's talk

I'm based in Boston and the Bay Area, and I'm looking for internships in robotics and mechanical design. Email is the best way to reach me.